Pololu Blog »
Flipbot: A Wixel-powered RC robot
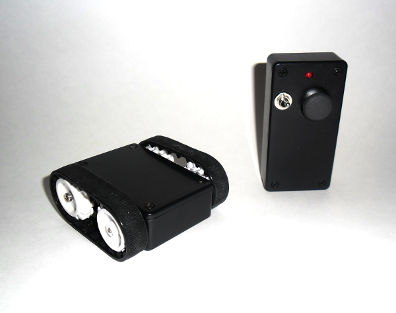 |
Geoff from Tabletop Robotics wrote a tutorial on how to build a Flipbot, a basic differential-drive robot that can keep on going even when flipped upside-down. A Wixel serves as the brains of the robot, and a second Wixel in the remote allows the Flipbot to be wirelessly controlled. In addition to the Wixels, the Flipbot uses a number of Pololu products, including:
- Two micro metal gearmotors
- 22T track set
- DRV8833 dual motor driver carrier
- MMA7361L 3-axis accelerometer
The accelerometer is used to determine when the robot is upside-down. Geoff’s tutorial has a full parts list and a diagram of how everything is connected; the complete source code is also available.
-
PiBot-B: mobile robot with a Raspberry Pi
- 23 October 2013Thomas Schoch, of Essen, Germany, built a neat robot with a Raspberry Pi and a Zumo Chassis Kit. The PiBot-B is controlled by a custom iPhone app...
-
Free Elektor magazine November 2013
- 23 October 2013Get a FREE copy of Elektor magazine’s November issue with your order while supplies last. To get your free issue, enter the coupon code ELEKTOR1113...
0 comments
Post a comment


Home | Forum | Blog | Support | Ordering Information | Lists | Distributors | BIG Order Form | About | Contact
© 2001–2026 Pololu Corporation